Focused-ultrasound registration and control
Registered imaging and tracking coordinates and implemented position control for focused-ultrasound field measurement.
01 / RESEARCH DETAILCoordinate registration and real-time image slices
- Challenge
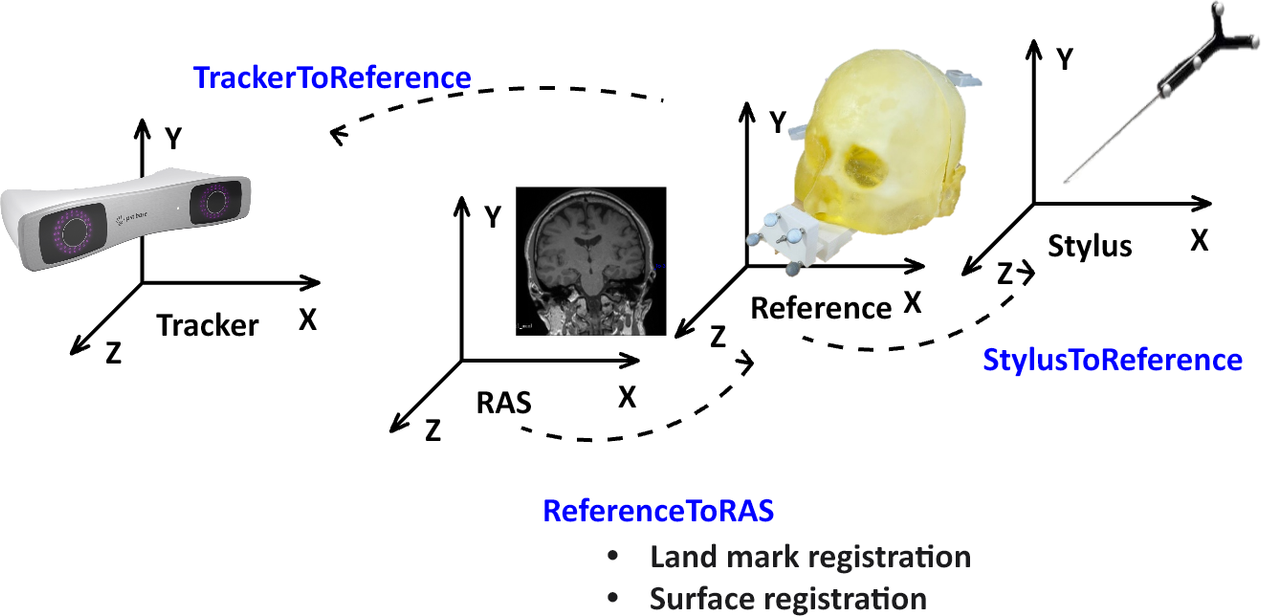
- CT/MRI volumes, tracking devices and probes use different coordinate systems.
- Approach
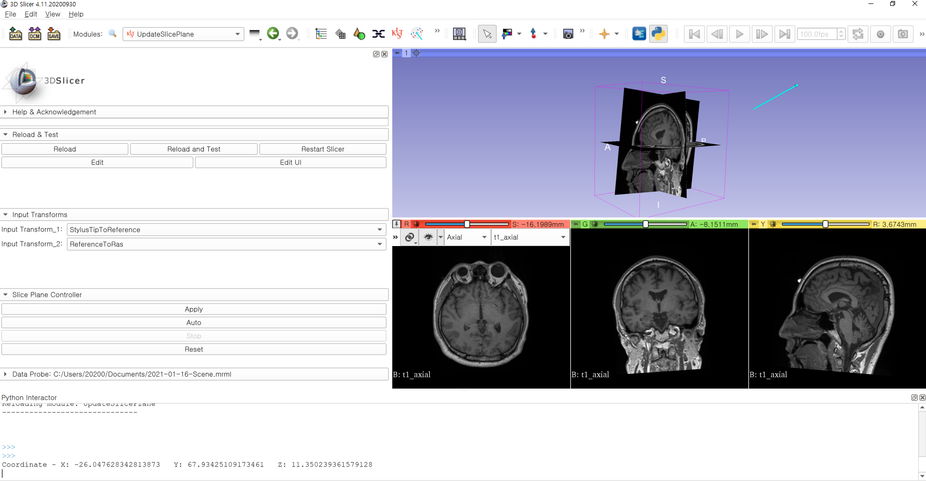
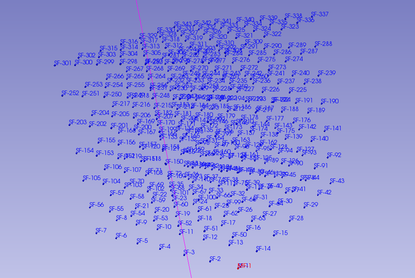
- Connected Reference and RAS coordinates through landmark and surface registration and propagated probe transforms to image slices in real time.
- Contribution
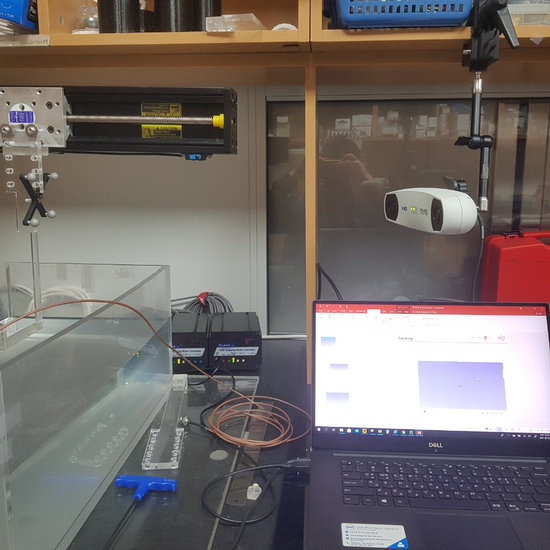
- Developed Python modules for 3D Slicer, integrated devices and packaged the prototype with preclinical researchers.
View full-size figure
View full-size figure
View full-size figure
| Module | Operation |
|---|---|
| Coordinate transform | ReferenceToRAS × TipToReference |
| Slice update | Update Red / Green / Yellow slice positions |
| Modules | Registration, tracking, stage control, acquisition |
Evaluation conditions and scopeImage guidance and device control in the KIST research prototype.
02 / RESEARCH DETAILStage movement, waveform acquisition and field maps
- Challenge
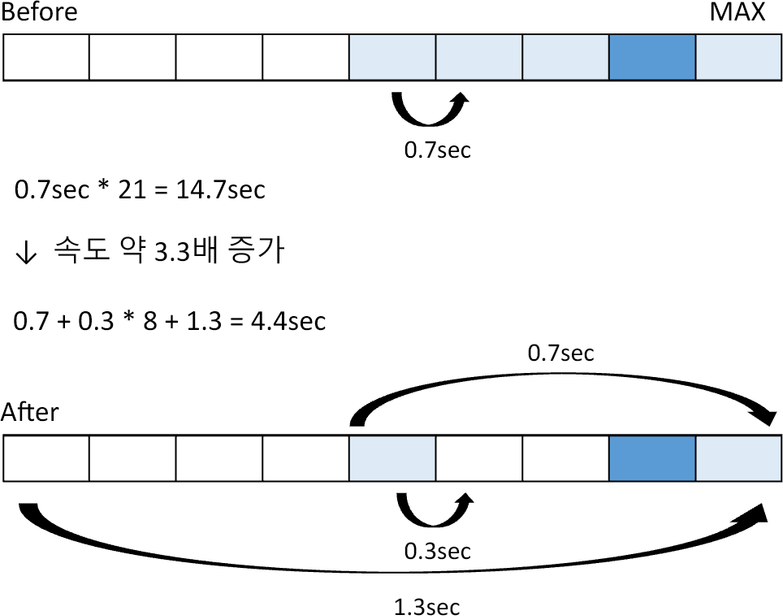
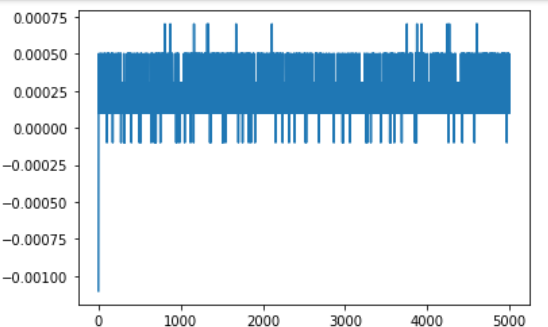
- Stage movements accumulate waiting time, and each waveform must remain associated with its measurement location.
- Approach
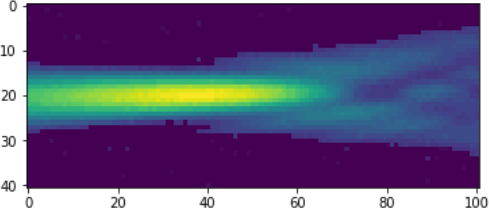
- Adjusted VXM movement intervals and waiting times and generated plane-wise field maps from grid measurements.
- Contribution
- Connected robotic movement, waveform acquisition and field visualization within 3D Slicer.
View full-size figure
View full-size figure
View full-size figure
View full-size figure
| Original timing comparison | Calculated time |
|---|---|
| Before | 0.7 × 21 = 14.7 s |
| After adjustment | 0.7 + 0.3 × 8 + 1.3 = 4.4 s |
| Speed ratio | Approximately 3.3× |
Evaluation conditions and scopeCalculated movement waiting time: 14.7 to 4.4 seconds, approximately 3.3 times faster.